























TIER IV and the Technical University of Munich announced on October 15, 2026 that they have established the TUM Autoware Research Center by TIER IV through a multi-year strategic research collaboration. The center brings together three TUM research groups working on Autoware, the open-source autonomous driving software that TIER IV develops and deploys.
The announcement states that the initiative aims to advance safe and scalable autonomous driving systems based on Autoware, strengthen TUM’s role as a leading contributor to the Autoware community in Europe, and accelerate the transfer of research into real-world mobility applications. The release describes Autoware as the world’s leading open-source software for autonomous driving.
Open-Source Background and the EDGAR Research Vehicle
In its background section, the announcement states that as vehicles become more autonomous, connected and software-defined, open-source software is becoming increasingly important to Europe’s automotive industry. It cites the European Commission’s concept paper on an open European software-defined vehicle platform as identifying a strong open-source strategy, reference implementations, standardized software components and shared validation tools as key foundations for European collaboration and competitiveness.
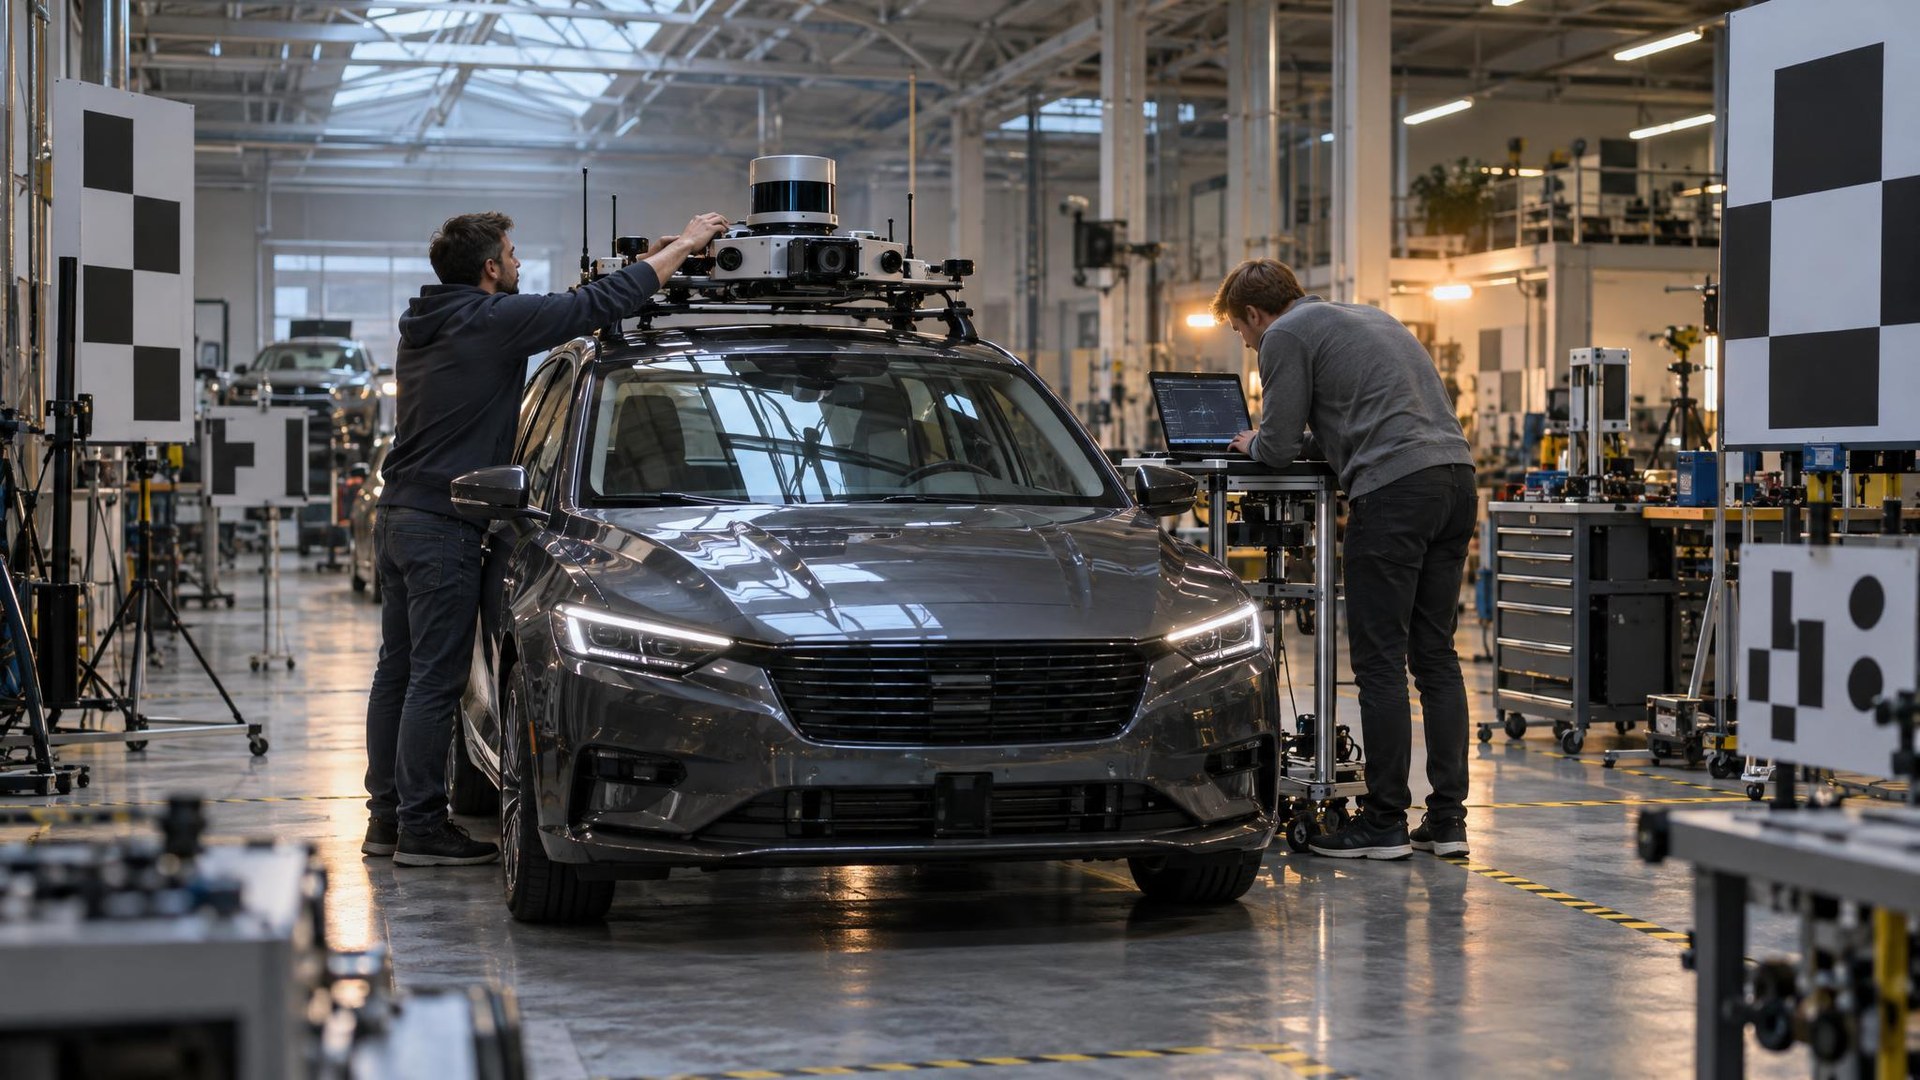
TUM already operates EDGAR, an autonomous research vehicle running the open-source Autoware software. At IAA MOBILITY 2025, EDGAR offered public demonstration rides from Messe München to downtown Munich across urban, rural and highway environments, a program the release presents as showcasing how open-source software, research and engineering can be integrated and evaluated under varied real-world traffic conditions.
TUM has also demonstrated rapid adaptation to a new city. Within a week, the TUM team deployed EDGAR in Berlin and demonstrated autonomous operation on the city’s urban roads, according to the release. The demonstration, run in collaboration with TÜV-Verband, tested a new assessment methodology for Level 4 autonomous driving under real-world traffic conditions for the German government.
Johannes Betz, Professor of Autonomous Vehicle Systems at TUM, said the university combines learning-based methods with traditional rule-based systems to make autonomous systems that can scale while remaining verifiably safe, and is deploying them in the real world. “Our autonomous research platform EDGAR is built upon the open-source software stack Autoware, which provides a great baseline for autonomous driving research and education,” he said.
Center Structure and Research Focus Areas
The center is established through strategic research funding from TIER IV and unites expertise from three TUM research groups: the Chair of Automotive Technology (FTM) and the Professorships of Cyber Physical Systems (CPS) and Autonomous Vehicle Systems (AVS). According to the release, the center will serve as a long-term base for autonomous driving research, open-source software development and doctoral training, connect academic, industrial and public-transport projects, and provide a platform for demonstrations and benchmark challenges.
The release sets out three research focus areas for the collaboration. The safety focus is the development of a hybrid architecture that combines deep-learning-based driving models with rule-based supervision, including a verifiable “safety guardian” that will monitor driving behavior and intervene when necessary based on defined safety constraints.
Under the evaluation focus, the partners will create a benchmarking and verification framework for component- and system-level testing across simulation, offline analysis and real-world operation, building on TUM’s EDGAR research platform and CommonRoad expertise. The scalability focus will establish a repeatable process for adapting and evaluating Autoware in new environments, with improvements contributed to open-source projects wherever appropriate.
Stated Goals for the Open Ecosystem
TIER IV and TUM said they intend the initiative to provide a foundation for expanding the open autonomous driving ecosystem in Germany and across Europe, connecting academic research, industrial development and public-transport projects. The partners said the collaboration aims to provide European vehicle manufacturers with technologies and evaluation methods that support the development of open, safe, scalable and product-oriented autonomous driving systems. Open software, shared evaluation methods and visible demonstrations will give organizations a common platform on which to test technologies, develop talent and advance autonomous mobility toward commercial and public use, they said.
“Safe autonomous driving at scale requires progress across AI, system architecture, verification and deployment,” said Shinpei Kato, founder and CEO of TIER IV. “By combining TUM’s research capabilities with TIER IV’s experience in developing and deploying Autoware, we aim to create technologies and open benchmarks that benefit the broader autonomous driving ecosystem. This collaboration also marks an important step toward advancing the open autonomous driving ecosystem in Europe, providing OEM manufacturers with technologies and evaluation methods that support the development of safe and scalable autonomous driving systems.”
Credit: Source link