• bitcoinBitcoin(BTC)$84,762.001.50%
  • ethereumEthereum(ETH)$2,714.752.58%
  • tetherTether(USDT)$1.000.01%
  • binancecoinBNB(BNB)$776.721.09%
  • rippleXRP(XRP)$1.566.07%
  • usd-coinUSDC(USDC)$1.000.01%
  • solanaSolana(SOL)$119.074.96%
  • tronTRON(TRX)$0.337060-0.78%
  • zcashZcash(ZEC)$1,600.689.03%
  • Figure HelocFigure Heloc(FIGR_HELOC)$1.030.00%
  • HyperliquidHyperliquid(HYPE)$94.273.42%
  • dogecoinDogecoin(DOGE)$0.0968024.46%
  • moneroMonero(XMR)$566.563.67%
  • chainlinkChainlink(LINK)$13.8813.69%
  • whitebitWhiteBIT Coin(WBT)$84.611.33%
  • USDSUSDS(USDS)$1.000.00%
  • cardanoCardano(ADA)$0.2526687.08%
  • RainRain(RAIN)$0.011900-0.83%
  • leo-tokenLEO Token(LEO)$8.83-0.95%
  • stellarStellar(XLM)$0.22113511.36%
  • bitcoin-cashBitcoin Cash(BCH)$337.741.93%
  • nearNEAR Protocol(NEAR)$4.9518.47%
  • uniswapUniswap(UNI)$9.344.60%
  • litecoinLitecoin(LTC)$70.545.85%
  • Ethena USDeEthena USDe(USDE)$1.000.01%
  • CantonCanton(CC)$0.11980512.26%
  • avalanche-2Avalanche(AVAX)$10.422.85%
  • daiDai(DAI)$1.000.00%
  • USD1USD1(USD1)$1.000.02%
  • suiSui(SUI)$1.0713.21%
  • hedera-hashgraphHedera(HBAR)$0.0937974.10%
  • the-open-networkGram (prev. Toncoin)(GRAM)$1.420.89%
  • BittensorBittensor(TAO)$303.887.78%
  • shiba-inuShiba Inu(SHIB)$0.0000064.85%
  • Global DollarGlobal Dollar(USDG)$1.000.01%
  • crypto-com-chainCronos(CRO)$0.0654708.01%
  • BitwayBitway(BTW)$1.108.14%
  • MemeCoreMemeCore(M)$1.19-3.44%
  • paypal-usdPayPal USD(PYUSD)$1.000.01%
  • tether-goldTether Gold(XAUT)$4,300.210.94%
  • OndoOndo(ONDO)$0.5529.50%
  • okbOKB(OKB)$120.341.83%
  • Circle USYCCircle USYC(USYC)$1.140.01%
  • Ripple USDRipple USD(RLUSD)$1.000.02%
  • EthenaEthena(ENA)$0.22833112.35%
  • BlackRock USD Institutional Digital Liquidity FundBlackRock USD Institutional Digital Liquidity Fund(BUIDL)$1.000.00%
  • Ondo US Dollar YieldOndo US Dollar Yield(USDY)$1.150.03%
  • aaveAave(AAVE)$145.696.57%
  • mantleMantle(MNT)$0.682.20%
  • MorphoMorpho(MORPHO)$2.907.77%
TradePoint.io
  • Main
  • AI & Technology
  • Stock Charts
  • Market & News
  • Business
  • Finance Tips
  • Trade Tube
  • Blog
  • Shop
No Result
View All Result
TradePoint.io
No Result
View All Result

Google DeepMind Researchers Propose RT-Affordance: A Hierarchical Method that Uses Affordances as an Intermediate Representation for Policies

November 8, 2024
in AI & Technology
Reading Time: 6 mins read
A A
Google DeepMind Researchers Propose RT-Affordance: A Hierarchical Method that Uses Affordances as an Intermediate Representation for Policies
ShareShareShareShareShare

In recent years, there has been significant development in the field of large pre-trained models for learning robot policies. The term “policy representation” here refers to the different ways of interfacing with the decision-making mechanisms of robots, which can potentially facilitate generalization to new tasks and environments. Vision-language-action (VLA) models are pre-trained with large-scale robot data to integrate visual perception, language understanding, and action-based decision-making to guide robots in various tasks. On top of vision-language models (VLMs), they come up with the promise of generalization to new objects, scenes, and tasks. However, VLAs still need to be more reliable to be deployed outside the narrow lab settings they are trained in. While these drawbacks can be mitigated by expanding the scope and diversity of robot datasets, this is highly resource-intensive and challenging to scale. In simple words, these policy representations either need to provide more context or over-specified context that yields less robust policies.


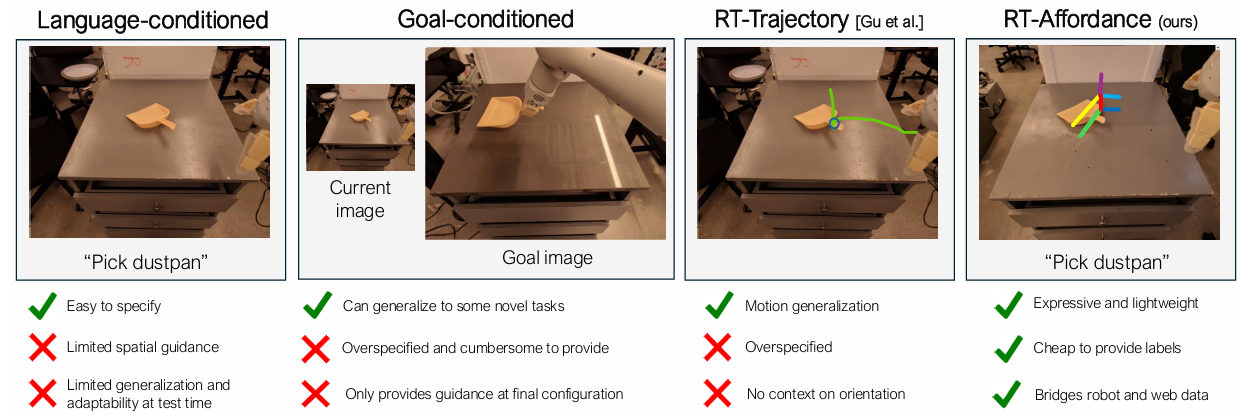
Existing policy representations such as language, goal images, and trajectory sketches are widely used and are helpful. One of the most common policy representations is conditioning on language. Most of the robot datasets are labeled with underspecified descriptions of the task, and language-based guidance does not provide enough guidance on how to perform the task. Goal image-conditioned policies provide detailed spatial information about the final goal configuration of the scene. However, goal images are high-dimensional, which presents learning challenges due to over-specification issues. Intermediate representation such as Trajectory sketches, or key points attempts to provide spatial plans for guiding the robot’s actions. While these spatial plans provide guidance, they still lack sufficient information for the policy on how to perform specific movements.
YOU MAY ALSO LIKE

Fastino Releases GLiNER2.5-Decide: A 340M Open-Weight Decision Model That Runs on CPU

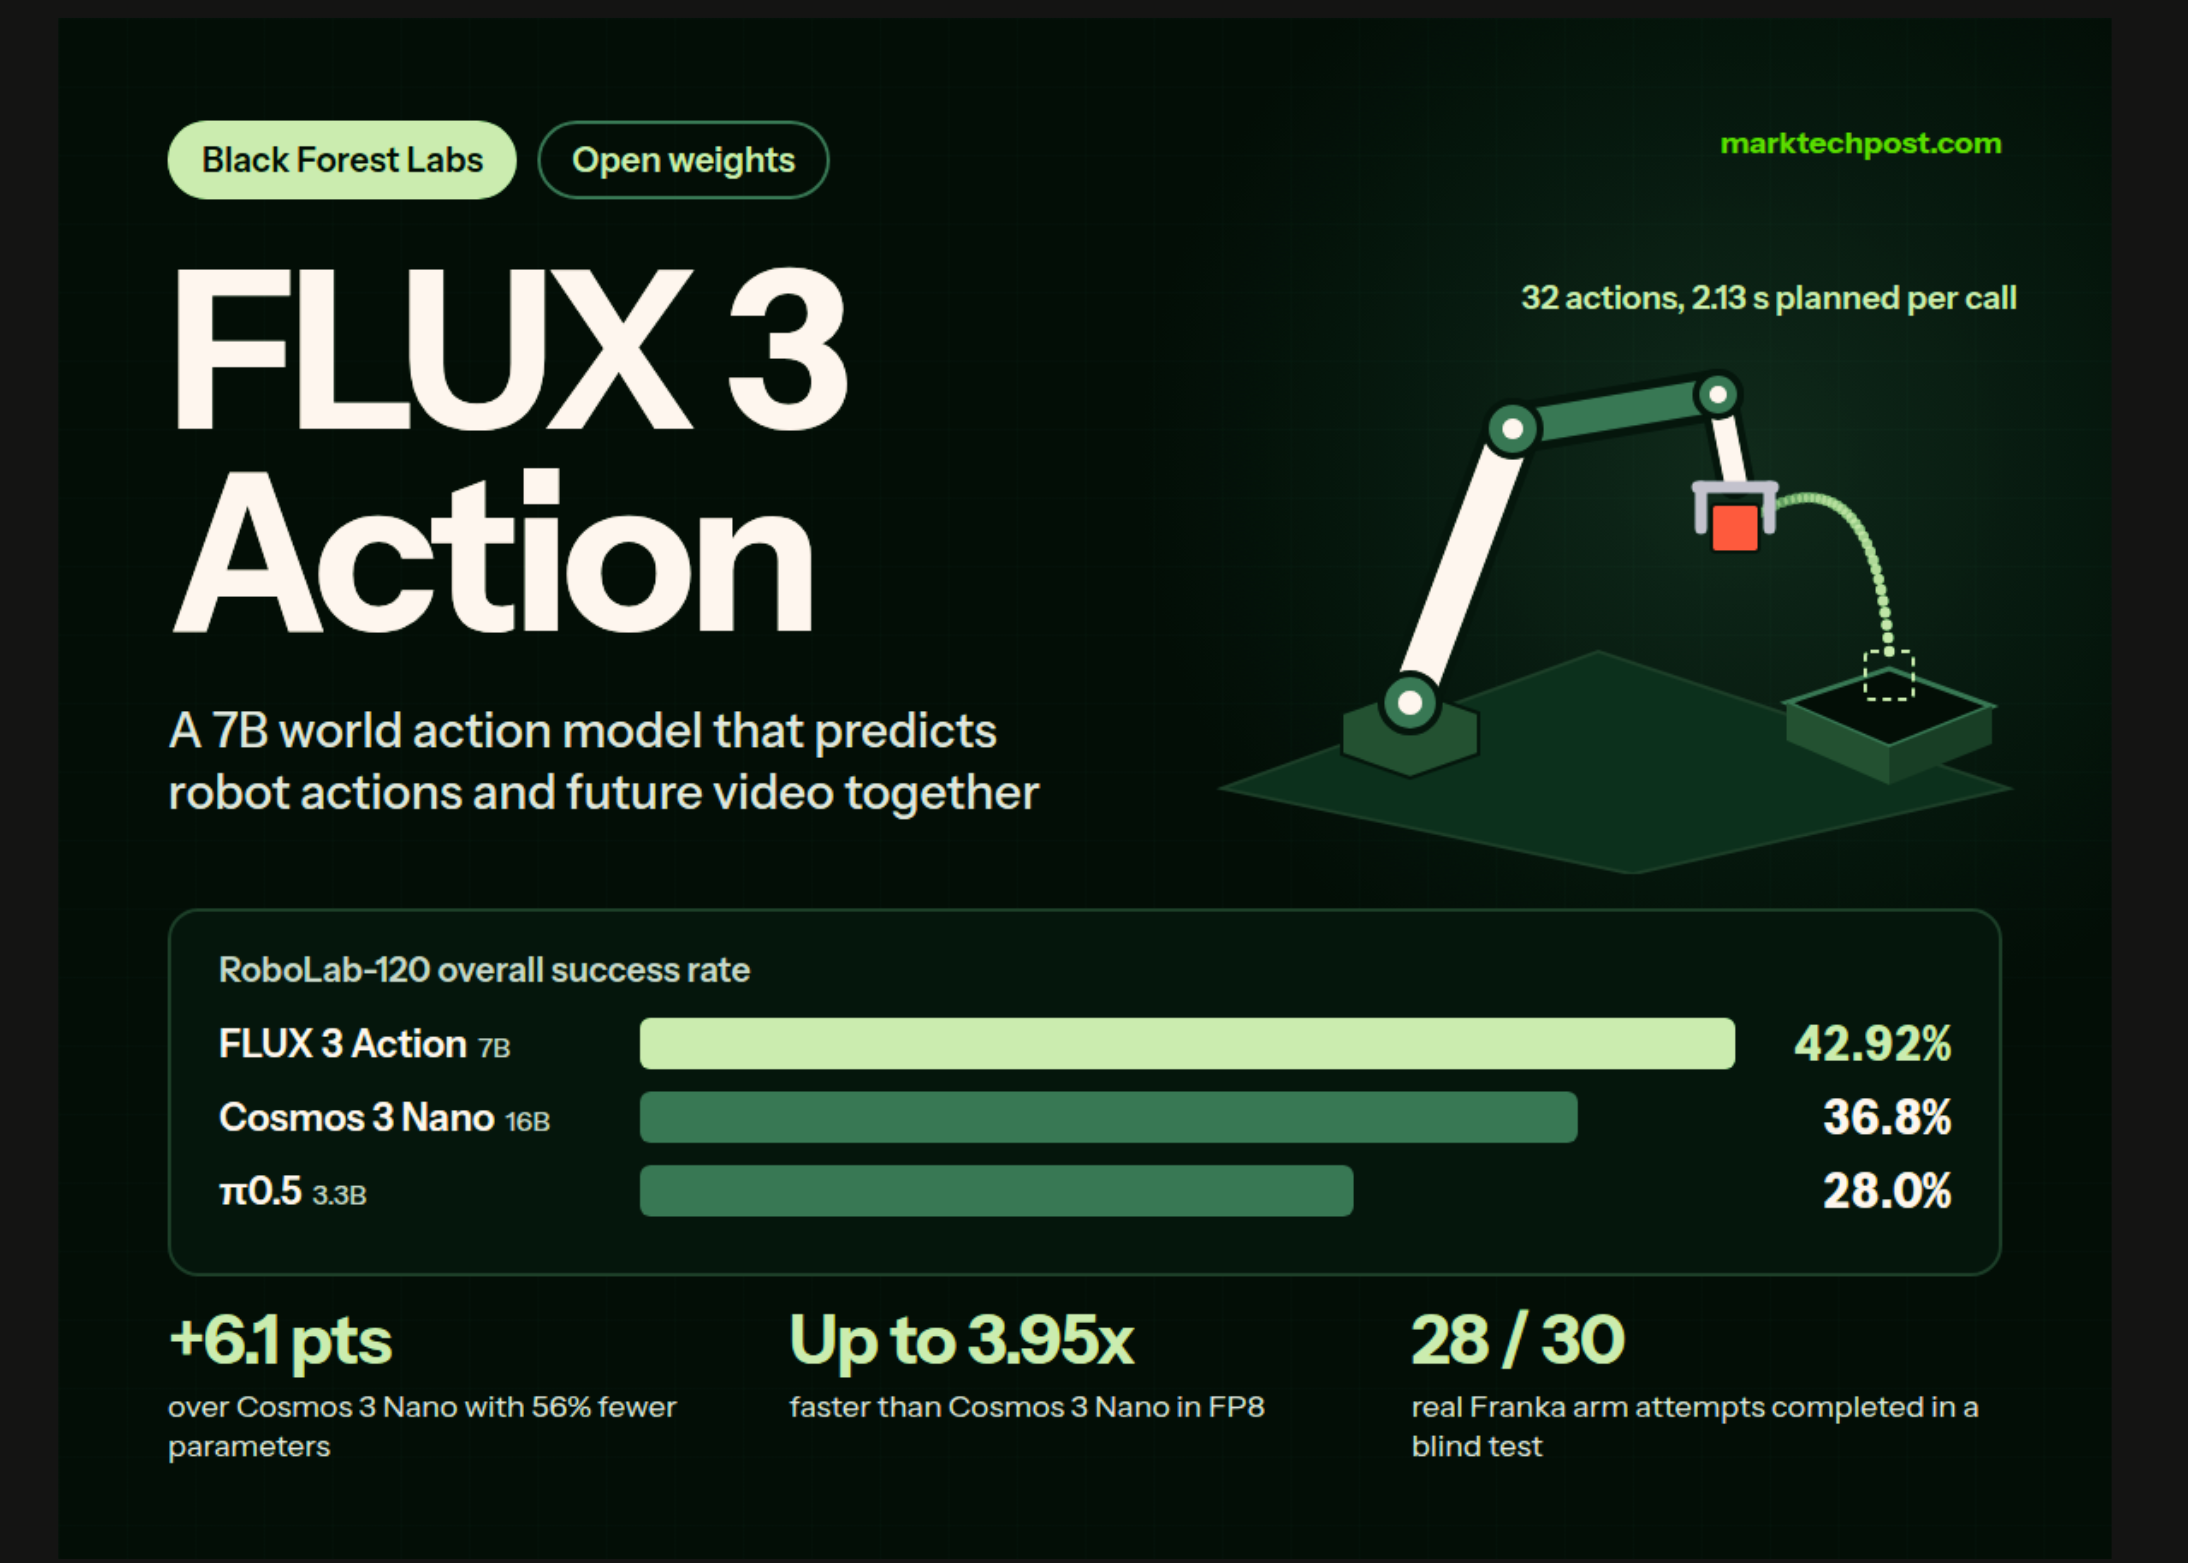
Black Forest Labs Releases FLUX 3 Action: A 7B Open-Weights World Action Model That Tops RoboLab-120

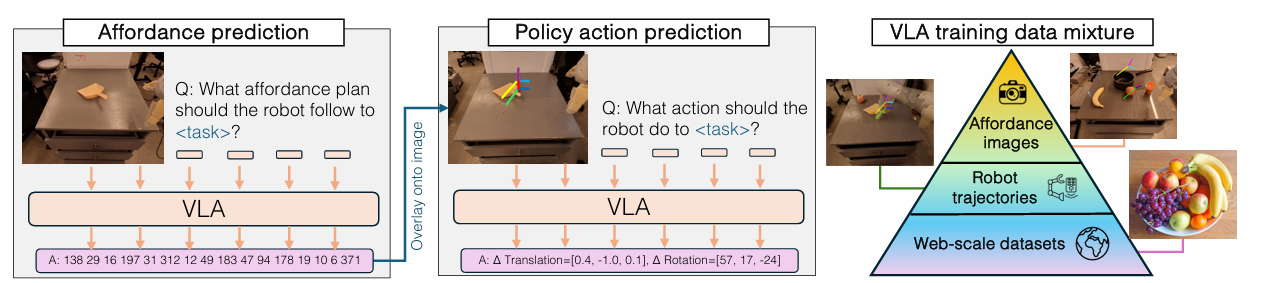
A team of researchers from Google DeepMind conducted detailed research on policy representation for robots and proposed RT-Affordance which is a hierarchical model that first creates an affordance plan given the task language, and then uses the policy on this affordance plan to guide the robot’s actions for manipulation. In robotics, affordance refers to the potential interactions that an object enables for a robot, based on its shape, size etc. The RT-Affordance model can easily connect heterogeneous sources of supervision including large web datasets and robot trajectories. 
First, the affordance plan is predicted for the given task language and the initial image of the task. This affordance plan is then combined with language instructions to condition the policy for task execution. It is then projected onto the image, and following this, the policy is conditioned on images overlaid with the affordance plan. The model is co-trained on web datasets (the largest data source), robot trajectories, and a modest number of cheap-to-collect images labeled with affordances. This approach benefits from leveraging both robot trajectory data and extensive web datasets, allowing the model to generalize well across new objects, scenes, and tasks.
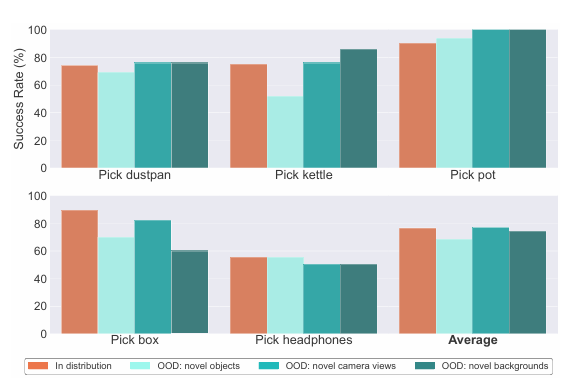
The research team conducted various experiments that mainly focused on how affordances help to improve robotic grasping, especially for movements of household items with complex shapes (like kettles, dustpans, and pots). A detailed evaluation showed that RT-A remains robust across various out-of-distribution (OOD) scenarios, such as novel objects, camera angles, and backgrounds. The RT-A model performed better than RT-2 and its goal-conditioned variant, achieving success rates of 68%-76% compared to RT-2’s 24%-28%. In tasks beyond grasping, like placing objects into containers, RT-A showed a significant performance with a 70% success rate. However, the performance of RT-A slightly dropped when it faced entirely new objects.
In conclusion, affordance-based policies are well-guided and also perform in a better way. The RT- Affordance method significantly improves the robustness and generalization of robot policies, which makes it a valuable tool for diverse manipulation tasks. Although it can not adapt to entirely new moments or skills, RT-Affordance surpasses traditional methods in terms of performance. This affordance technique opens the gate for various future research opportunities in robotics and can serve as a baseline for future studies!


Check out the Paper. All credit for this research goes to the researchers of this project. Also, don’t forget to follow us on Twitter and join our Telegram Channel and LinkedIn Group. If you like our work, you will love our newsletter.. Don’t Forget to join our 55k+ ML SubReddit.

[Sponsorship Opportunity with us] Promote Your Research/Product/Webinar with 1Million+ Monthly Readers and 500k+ Community Members

Divyesh is a consulting intern at Marktechpost. He is pursuing a BTech in Agricultural and Food Engineering from the Indian Institute of Technology, Kharagpur. He is a Data Science and Machine learning enthusiast who wants to integrate these leading technologies into the agricultural domain and solve challenges.

Listen to our latest AI podcasts and AI research videos here ➡️


Credit: Source link

ShareTweetSendSharePin

Related Posts

Fastino Releases GLiNER2.5-Decide: A 340M Open-Weight Decision Model That Runs on CPU
AI & Technology

Fastino Releases GLiNER2.5-Decide: A 340M Open-Weight Decision Model That Runs on CPU

September 25, 2026
Black Forest Labs Releases FLUX 3 Action: A 7B Open-Weights World Action Model That Tops RoboLab-120
AI & Technology

Black Forest Labs Releases FLUX 3 Action: A 7B Open-Weights World Action Model That Tops RoboLab-120

September 25, 2026
Warzone Is Adding A Button To Hide All The Goofy Skins
AI & Technology

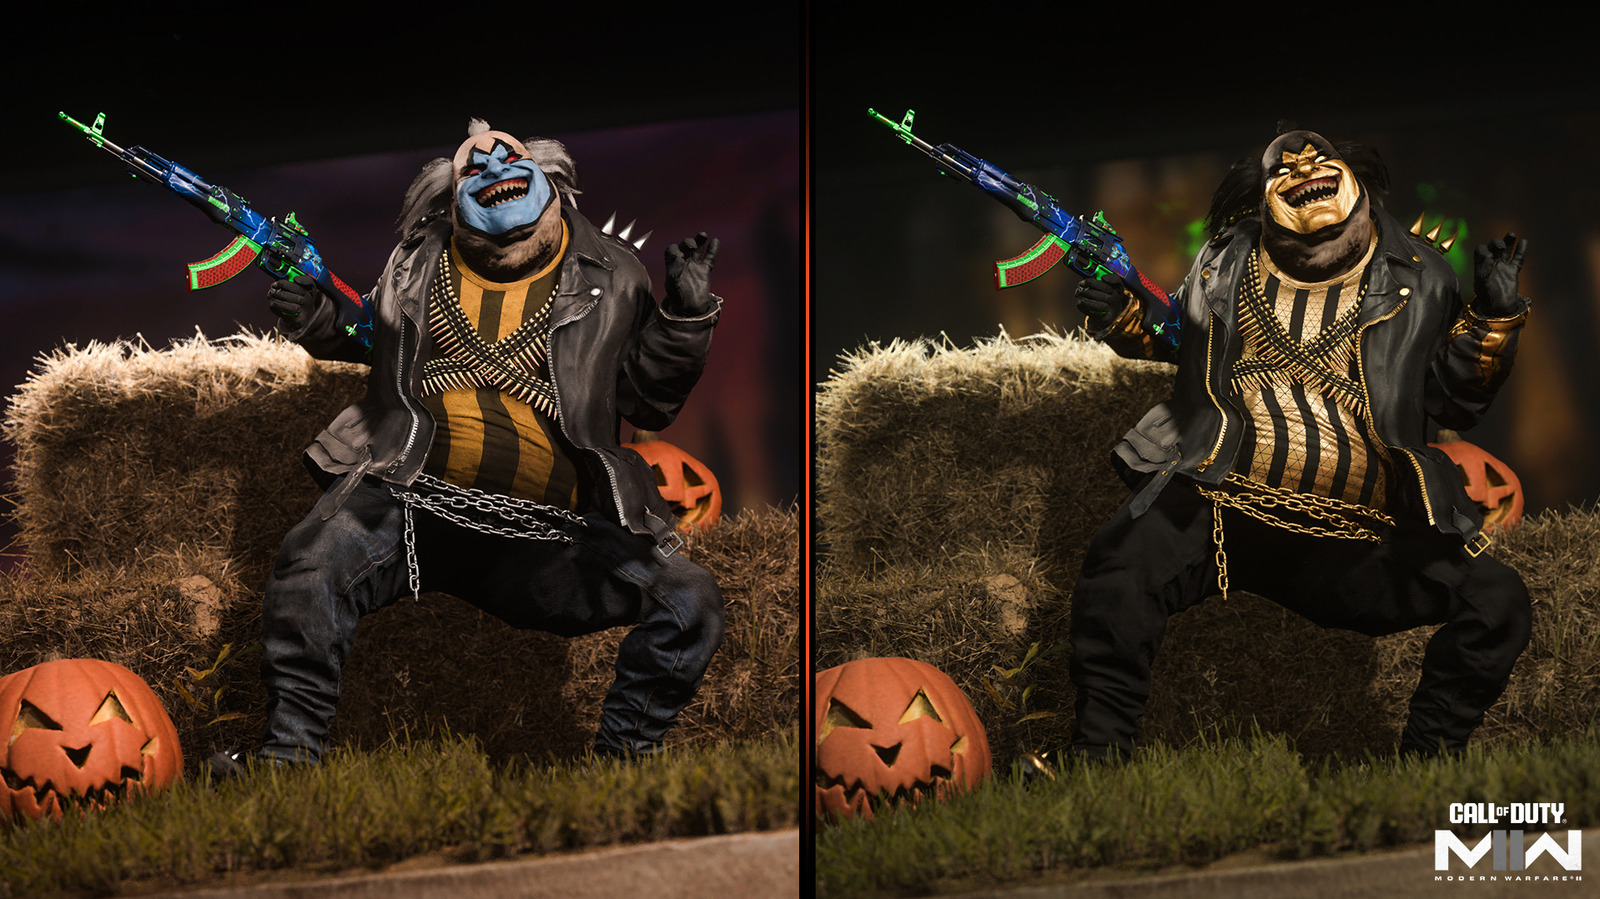
Warzone Is Adding A Button To Hide All The Goofy Skins

September 24, 2026
How These AI Glasses Compare
AI & Technology

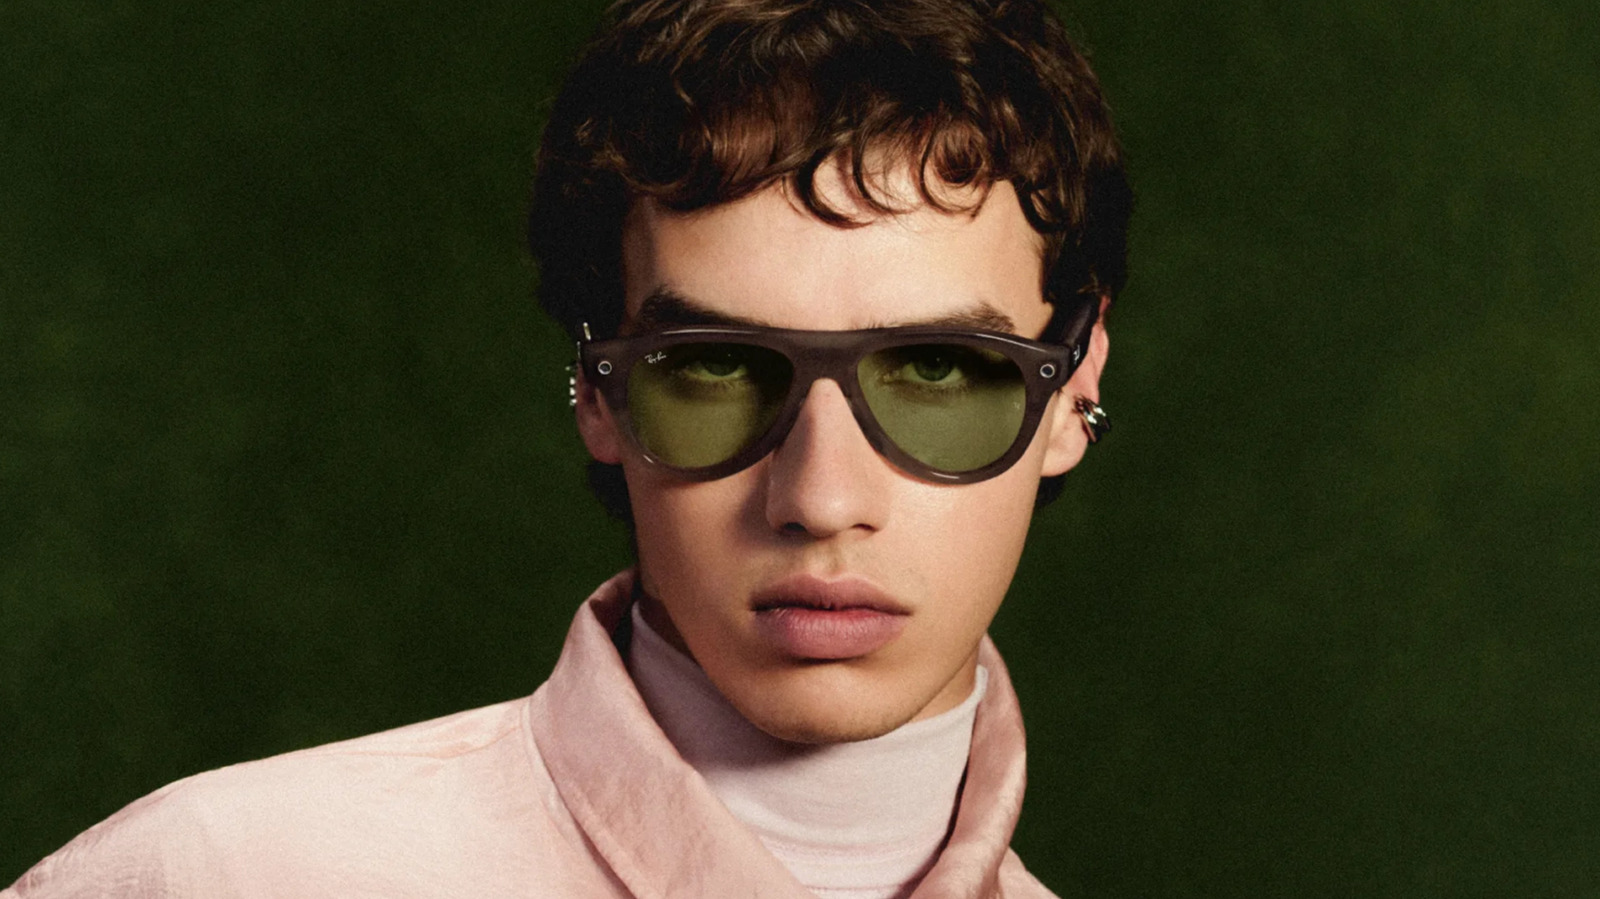
How These AI Glasses Compare

September 24, 2026
Next Post
Apple Intelligence includes email writing tools, ‘clean up’ images feature

Apple Intelligence includes email writing tools, ‘clean up’ images feature

Leave a Reply Cancel reply

Your email address will not be published. Required fields are marked *

Search

No Result
View All Result
New hearing in Idaho college murders case

New hearing in Idaho college murders case

September 22, 2026
Brendan Hunt on the future of ‘Ted Lasso’ and how a rejection led him to get Coach Beard

Brendan Hunt on the future of ‘Ted Lasso’ and how a rejection led him to get Coach Beard

September 24, 2026
Warner Bros. Discovery: Closing A Merger Can Be A Real Challenge

Warner Bros. Discovery: Closing A Merger Can Be A Real Challenge

September 22, 2026

About

Learn more

Our Services

Legal

Privacy Policy

Terms of Use

Bloggers

Learn more

Article Links

Contact

Advertise

Ask us anything

©2020- TradePoint.io - All rights reserved!

Tradepoint.io, being just a publishing and technology platform, is not a registered broker-dealer or investment adviser. So we do not provide investment advice. Rather, brokerage services are provided to clients of Tradepoint.io by independent SEC-registered broker-dealers and members of FINRA/SIPC. Every form of investing carries some risk and past performance is not a guarantee of future results. “Tradepoint.io“, “Instant Investing” and “My Trading Tools” are registered trademarks of Apperbuild, LLC.

This website is operated by Apperbuild, LLC. We have no link to any brokerage firm and we do not provide investment advice. Every information and resource we provide is solely for the education of our readers. © 2020 Apperbuild, LLC. All rights reserved.

No Result
View All Result
  • Main
  • AI & Technology
  • Stock Charts
  • Market & News
  • Business
  • Finance Tips
  • Trade Tube
  • Blog
  • Shop

© 2023 - TradePoint.io - All Rights Reserved!